 HackerTube.runGood videos, with context.
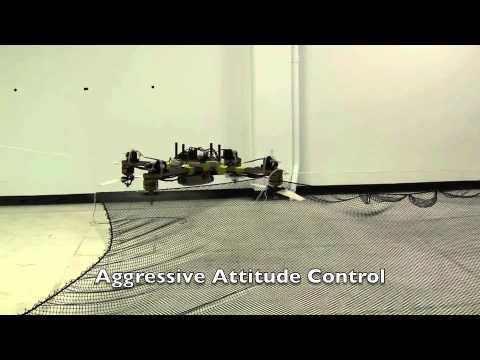
MIT ACL - Variable Pitch Quadrotor
About this video
A short MIT Aerospace Controls Lab demo from 2011 of a variable pitch quadrotor flying.
Why it appears in the archive
Referenced in drone threads as a demonstration that variable pitch quadcopters fly well with little drift.
AI-generated summary and labels from the source dataset; verify important details against the video. Source & credits.
From the Hacker News discussion
The example you posted has far more things in common with a multirotor than with a helicopter. What amazes me at those little things is how little side-to-side drift they have, considering that's all depending on the CG being well centered. A nice variable pitch quad: [VIDEO]
Read original comment ↗Are there other types of drones other than traditional quadcopters, for example variable-pitch quadcopters [1], that can get more airspeed and thus cover more distance in 15 min? What about using airplane-style drones (like traditional RC planes) + a parachute to land the package? And this way you could use nitro gas fuel to get better energy density (since you can use one big gas engine instead of having to use four tiny motors) [1] [VIDEO]
Read original comment ↗Manned multicopters have already happened. [1] MIT has also demonstrated a variable pitch quadcopter. [2] If they can use plasma laminar detachment and reattachment to somehow simulate a variable pitch propeller, while still getting some weight savings over a design with multiple swashplates, then yes I think it should help the quadcopter design scale up to larger propellers. That's a big if though, since to simulate a negative angle of attack I'm guessing your propeller design would have to be pretty inefficient with all plasma turned off. I'm not entirely sure why you want this though, since the single large rotor is more efficient. There was a novel design a few years ago with one large rotor for lift and three smaller ones to counter torque and provide control. [3] [1] [LINK] [2] [VIDEO] [3] [LINK]
Read original comment ↗